
triki-controller
v0.3.0
Published
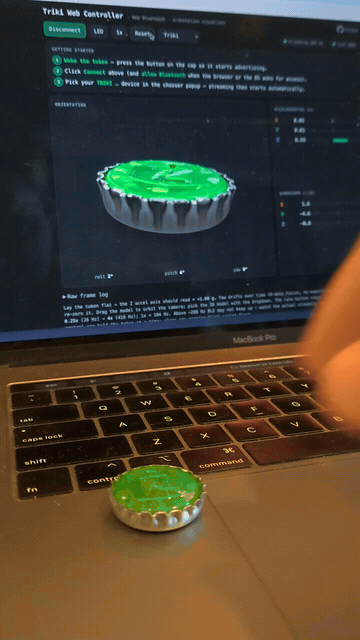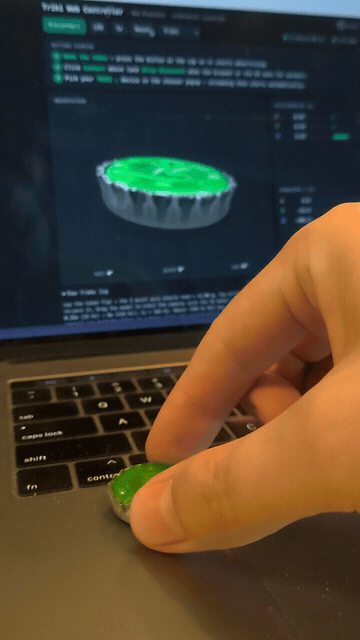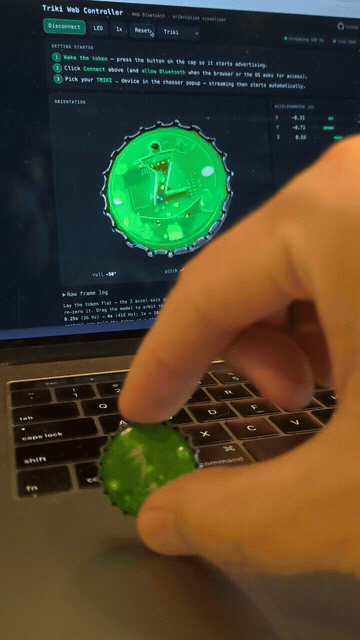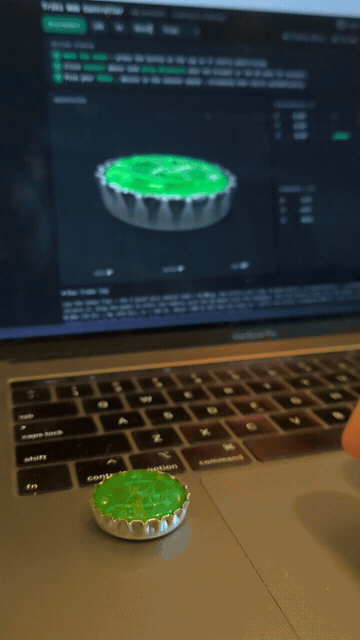
Driver for the Żabka Triki token (nRF52810 + LSM6DSL) — connect, stream the IMU, and read fused orientation (selectable Madgwick or VQF) to reuse the token as a motion controller. Web Bluetooth in the browser, or @abandonware/noble in Node.

Maintainers
 flopbut
Readme
triki-controller
A strongly-typed driver for the Żabka Triki
BLE token (an nRF52810 BLE SoC + LSM6DSL accelerometer/gyroscope, shaped like a bottle cap).
It connects over the Nordic UART Service, starts the IMU stream, parses the 14-byte motion
frames, and optionally fuses orientation with a selectable 6-axis filter — Madgwick or
VQF — so you can reuse the token as a motion controller. Web Bluetooth in the
browser (zero runtime dependencies), or Node via the optional
@abandonware/noble transport.
Browser support
In the browser, Web Bluetooth is required (see Node.js & custom transports for everything else):
- ✅ Desktop Chrome / Edge / Opera (Chromium-based).
- ❌ Safari and Firefox do not implement Web Bluetooth.
- Must run in a secure context —
https://orhttp://localhost. Notfile://. connect()must be called from a user gesture (e.g. a click handler).- One BLE central connects at a time.
Install
npm install triki-controllerQuick start
import { TrikiController } from "triki-controller";

if (!TrikiController.isSupported()) {
  throw new Error("This browser has no Web Bluetooth.");
}

const triki = new TrikiController({ fusion: true, rateHz: 104 });

triki.on("connectionchange", (state) => {
  console.log("state:", state); // "disconnected" | "pairing" | "streaming"
});

triki.on("frame", (f) => {
  // f.gyro = { x, y, z } in deg/s, f.accel = { x, y, z } in g, f.t = ms
});

triki.on("orientation", (o) => {
  // o.quaternion = [w, x, y, z] (right-handed), o.euler = { roll, pitch, yaw } in degrees
});

triki.on("rate", (hz) => {
  console.log("streaming", hz, "Hz");
});

// Must be inside a click/tap handler:
document.querySelector("#connect")!.addEventListener("click", async () => {
  await triki.connect();
  await triki.setLed(true);     // green LED on
  await triki.setRate(208);     // bump the sample rate (26 / 52 / 104 / 208 / 416 Hz)
  triki.resetHeading();         // re-zero yaw whenever you like
});
Pick the filter with fusion: "madgwick" (default), "vqf", "accel" (accelerometer-only
tilt — instant but jittery, no yaw), or "none" (true≡madgwick, false≡none). Raw frames
only: { fusion: "none" }, listen to "frame". Switch live with setFusion(...). The
MadgwickAHRS, VqfAHRS, AccelAHRS and FrameParser classes are also exported and usable
standalone (the filters share an OrientationFilter interface).
API
new TrikiController(options?) — options: fusion? ("madgwick"/"vqf"/"accel"/"none",
default "madgwick"), rateHz? (default 104), beta? (Madgwick gain, default 0.08),
tauAcc? (VQF accel low-pass seconds, default 2.0), gyroScale? (default 14.286),
gyroBias? / accelBias? (per-axis correction vectors, default zeros), transport?
(a TrikiTransport; defaults to the browser's WebBluetoothTransport).
| Member | Description |
| --- | --- |
| static isSupported() | true when navigator.bluetooth exists (SSR-safe). Only about the default Web Bluetooth transport — in Node with NobleTransport just call connect(). |
| connect() | Show the picker, connect, start streaming. User gesture required. |
| reconnect() | Reconnect to the last paired device without the picker. |
| disconnect() | Disconnect. Idempotent; safe in any state — cancels a pending connect(). |
| dispose() | Disconnect, release the transport (another controller may then attach), drop all listeners. |
| setLed(on) | Green LED on/off (throws if the token has no LED characteristic). |
| setRate(hz) | Set sample rate; applied live when streaming. |
| resetHeading() | Re-zero yaw (no-op when fusion is off). |
| setFusion(algo) | Switch filter at runtime ("madgwick"/"vqf"/"accel"/"none"). |
| setBeta(v) / setTauAcc(v) | Tune the active Madgwick / VQF filter live. |
| setGyroScale(scale) | Runtime gyro calibration. |
| setGyroBias(v) / setAccelBias(v) | Set the per-axis correction vectors live. |
| isConnected / state / rateHz / hasLed / battery / fusion / fusionAlgorithm | Getters. |
| on(type, cb) / once / off | Typed subscription; on/once return an unsubscribe fn. |
Events: frame, orientation (fusion only), connectionchange (payload is the state string),
rate (measured Hz), battery (level in percent, 0–100).
Node.js & custom transports
The BLE link is pluggable: pass any TrikiTransport via the transport option. To
receive the token from a plain Node process, use the NobleTransport from the
triki-controller/node entry (backed by the optional peer dependency
@abandonware/noble — installed separately, imported lazily):
npm install triki-controller @abandonware/nobleimport { TrikiController, NobleTransport } from "triki-controller/node";
const triki = new TrikiController({ transport: new NobleTransport() });
triki.on("orientation", (o) => console.log(o.euler));
await triki.connect(); // scans for a "TRIKI" token (15 s budget), connects, streamsOptions, timeout/cancellation semantics, the full TrikiTransport contract, and a
runnable example live in the
library guide
and example/node.mjs.
Caveats
- Yaw drift. Fusion is 6-axis (gyro + accel, no magnetometer), so absolute heading drifts
over time. Roll/pitch stay levelled by gravity. Call
resetHeading()to re-zero yaw. - Math vs display frame. This library emits the right-handed math quaternion. The Triki
demo page negates
yandz([w, x, -y, -z]) only for its on-screen roll/pitch/yaw readout (the 3D model is driven from the unmodified quaternion) — apply that negation yourself only if you mirror that readout; don't double-negate. - Throughput. Above ~208 Hz, BLE may not keep up; the
rateevent reports the actual measured throughput so you can react.
License
MIT © Flopsstuff